|
Janghyun Cho I am a Master's student in Artificial Intelligence at Sogang University, advised by Prof. Changjoo Nam. My research interests include multi-robot systems, path planning, and autonomous exploration. I did my Bachelor's degree in Software Convergence (Robot Vision track) at Kyung Hee University. "The greatest inventions in human history are the wheel and the motor." Email / LinkedIn / Technical Blog (Korean) / Scholar / Github |
|
ResearchI'm interested in multi-robot systems, autonomous exploration, and multi-agent path planning. |
Submitted |

|
Safe Navigation of Heterogeneous Mobile Robot Teams
Joonkyung Kim, Janghyun Cho, Jeehyun Lee, Changjoo Nam, Yiwei Lyu Submitted, 2026 This formulation provides a common geometric representation of safety across heterogeneous robots whileretaining their model-specific dynamics and admissible control constraints. |
|
Decentralized Multi-Agent Exploration without Communication under Budget Constraints
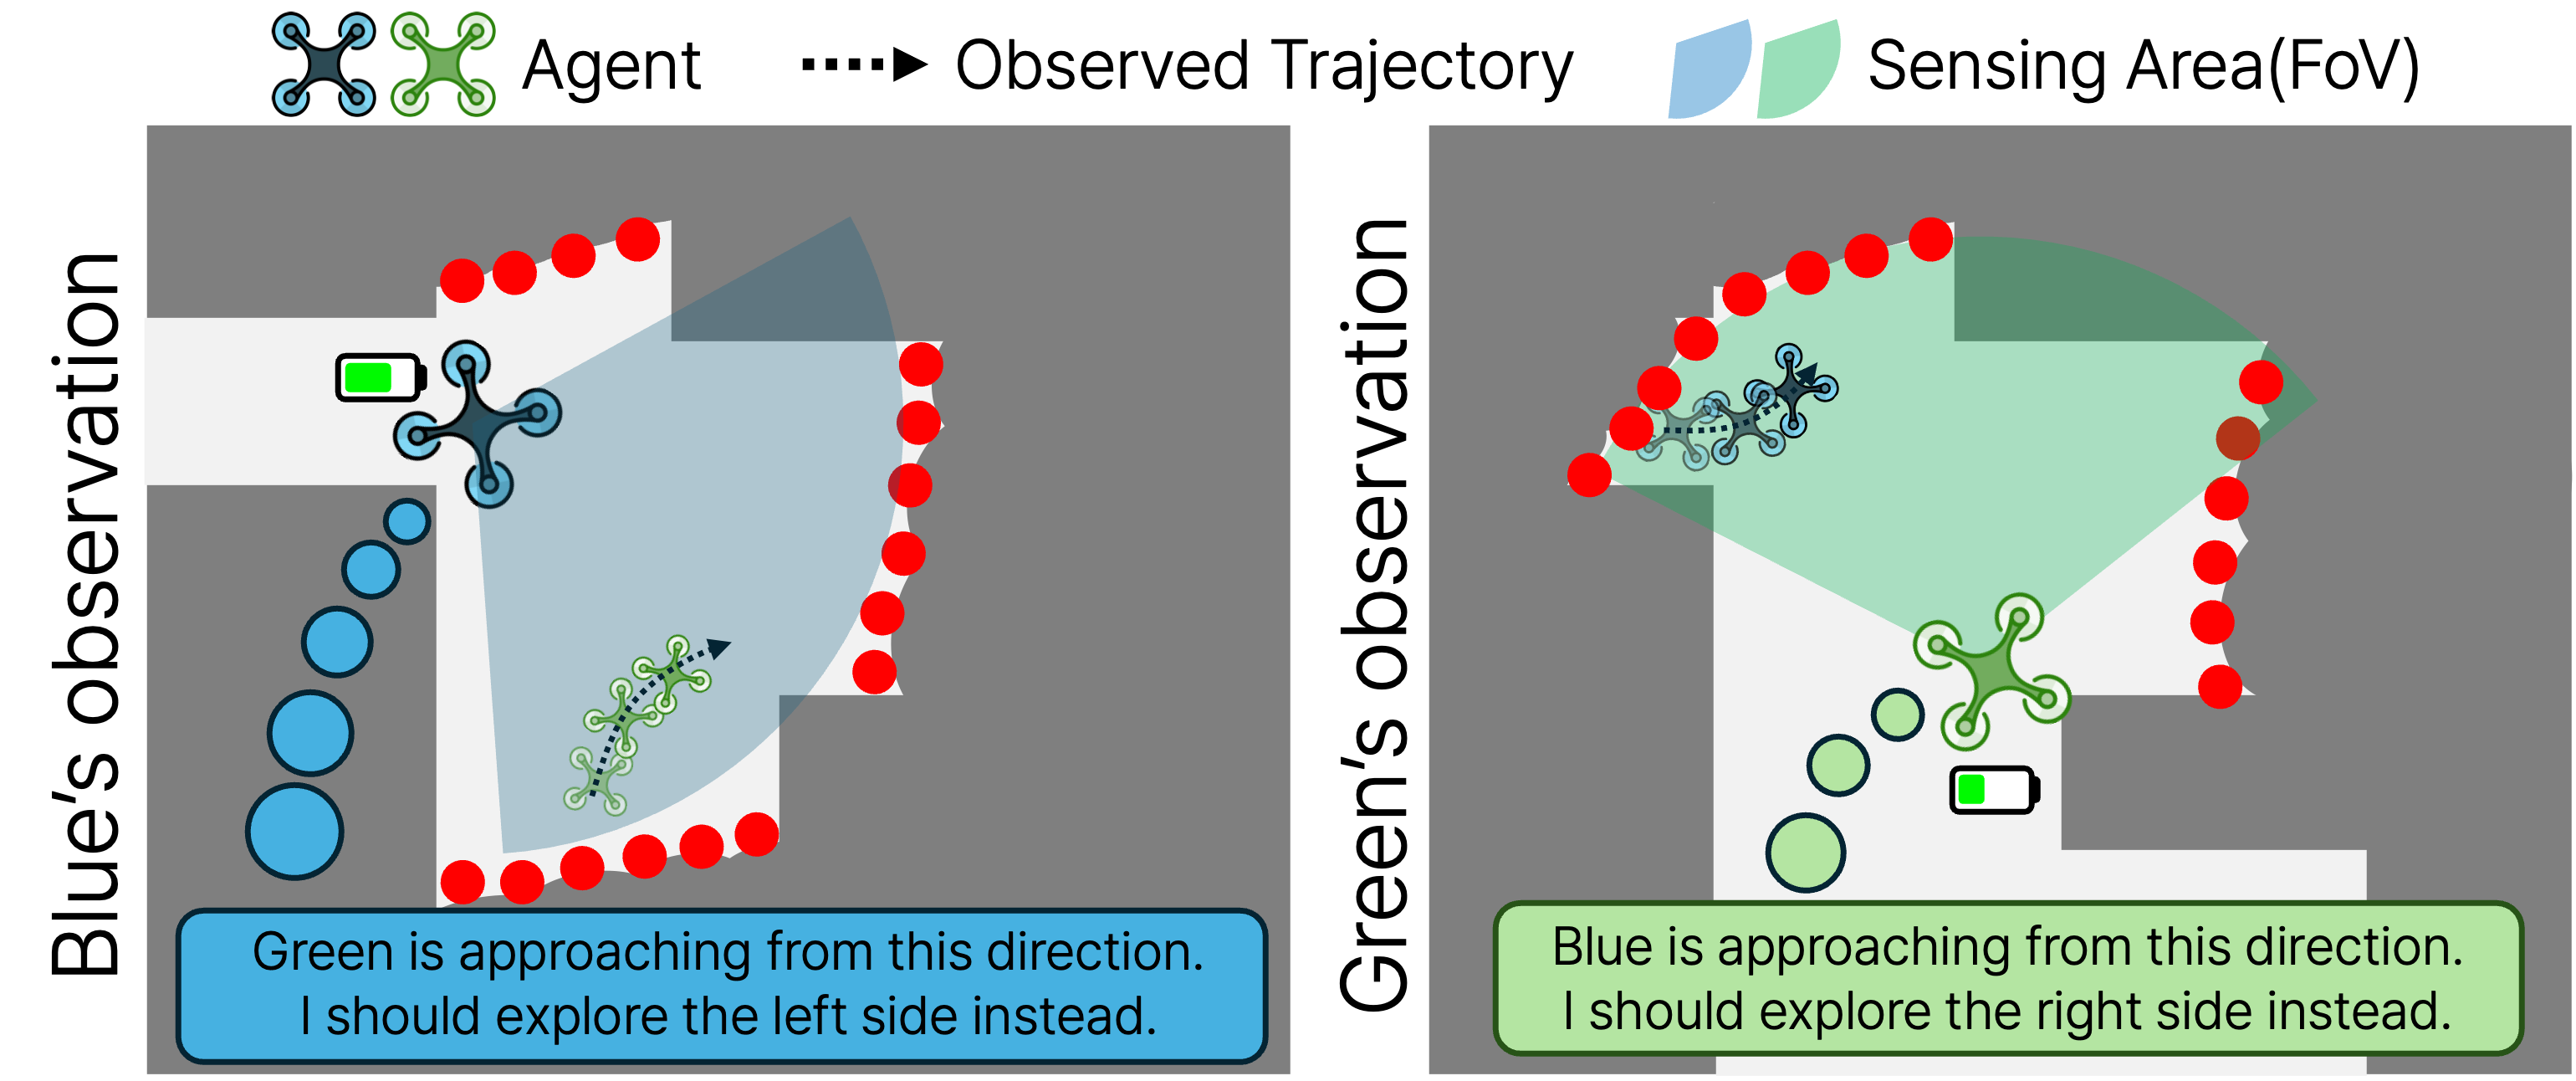
Janghyun Cho*, Jimmy Chiun*, Guillaume Sartoretti , Changjoo Nam Submitted, 2026 A decentralized budget-aware exploration framework for communication-free teams with directional sensing. Rather than exchanging maps, goals, or messages, each robot coordinates through its incidental observations. |
|
Scalable Multi-Robot Path Planning in Continuous Space
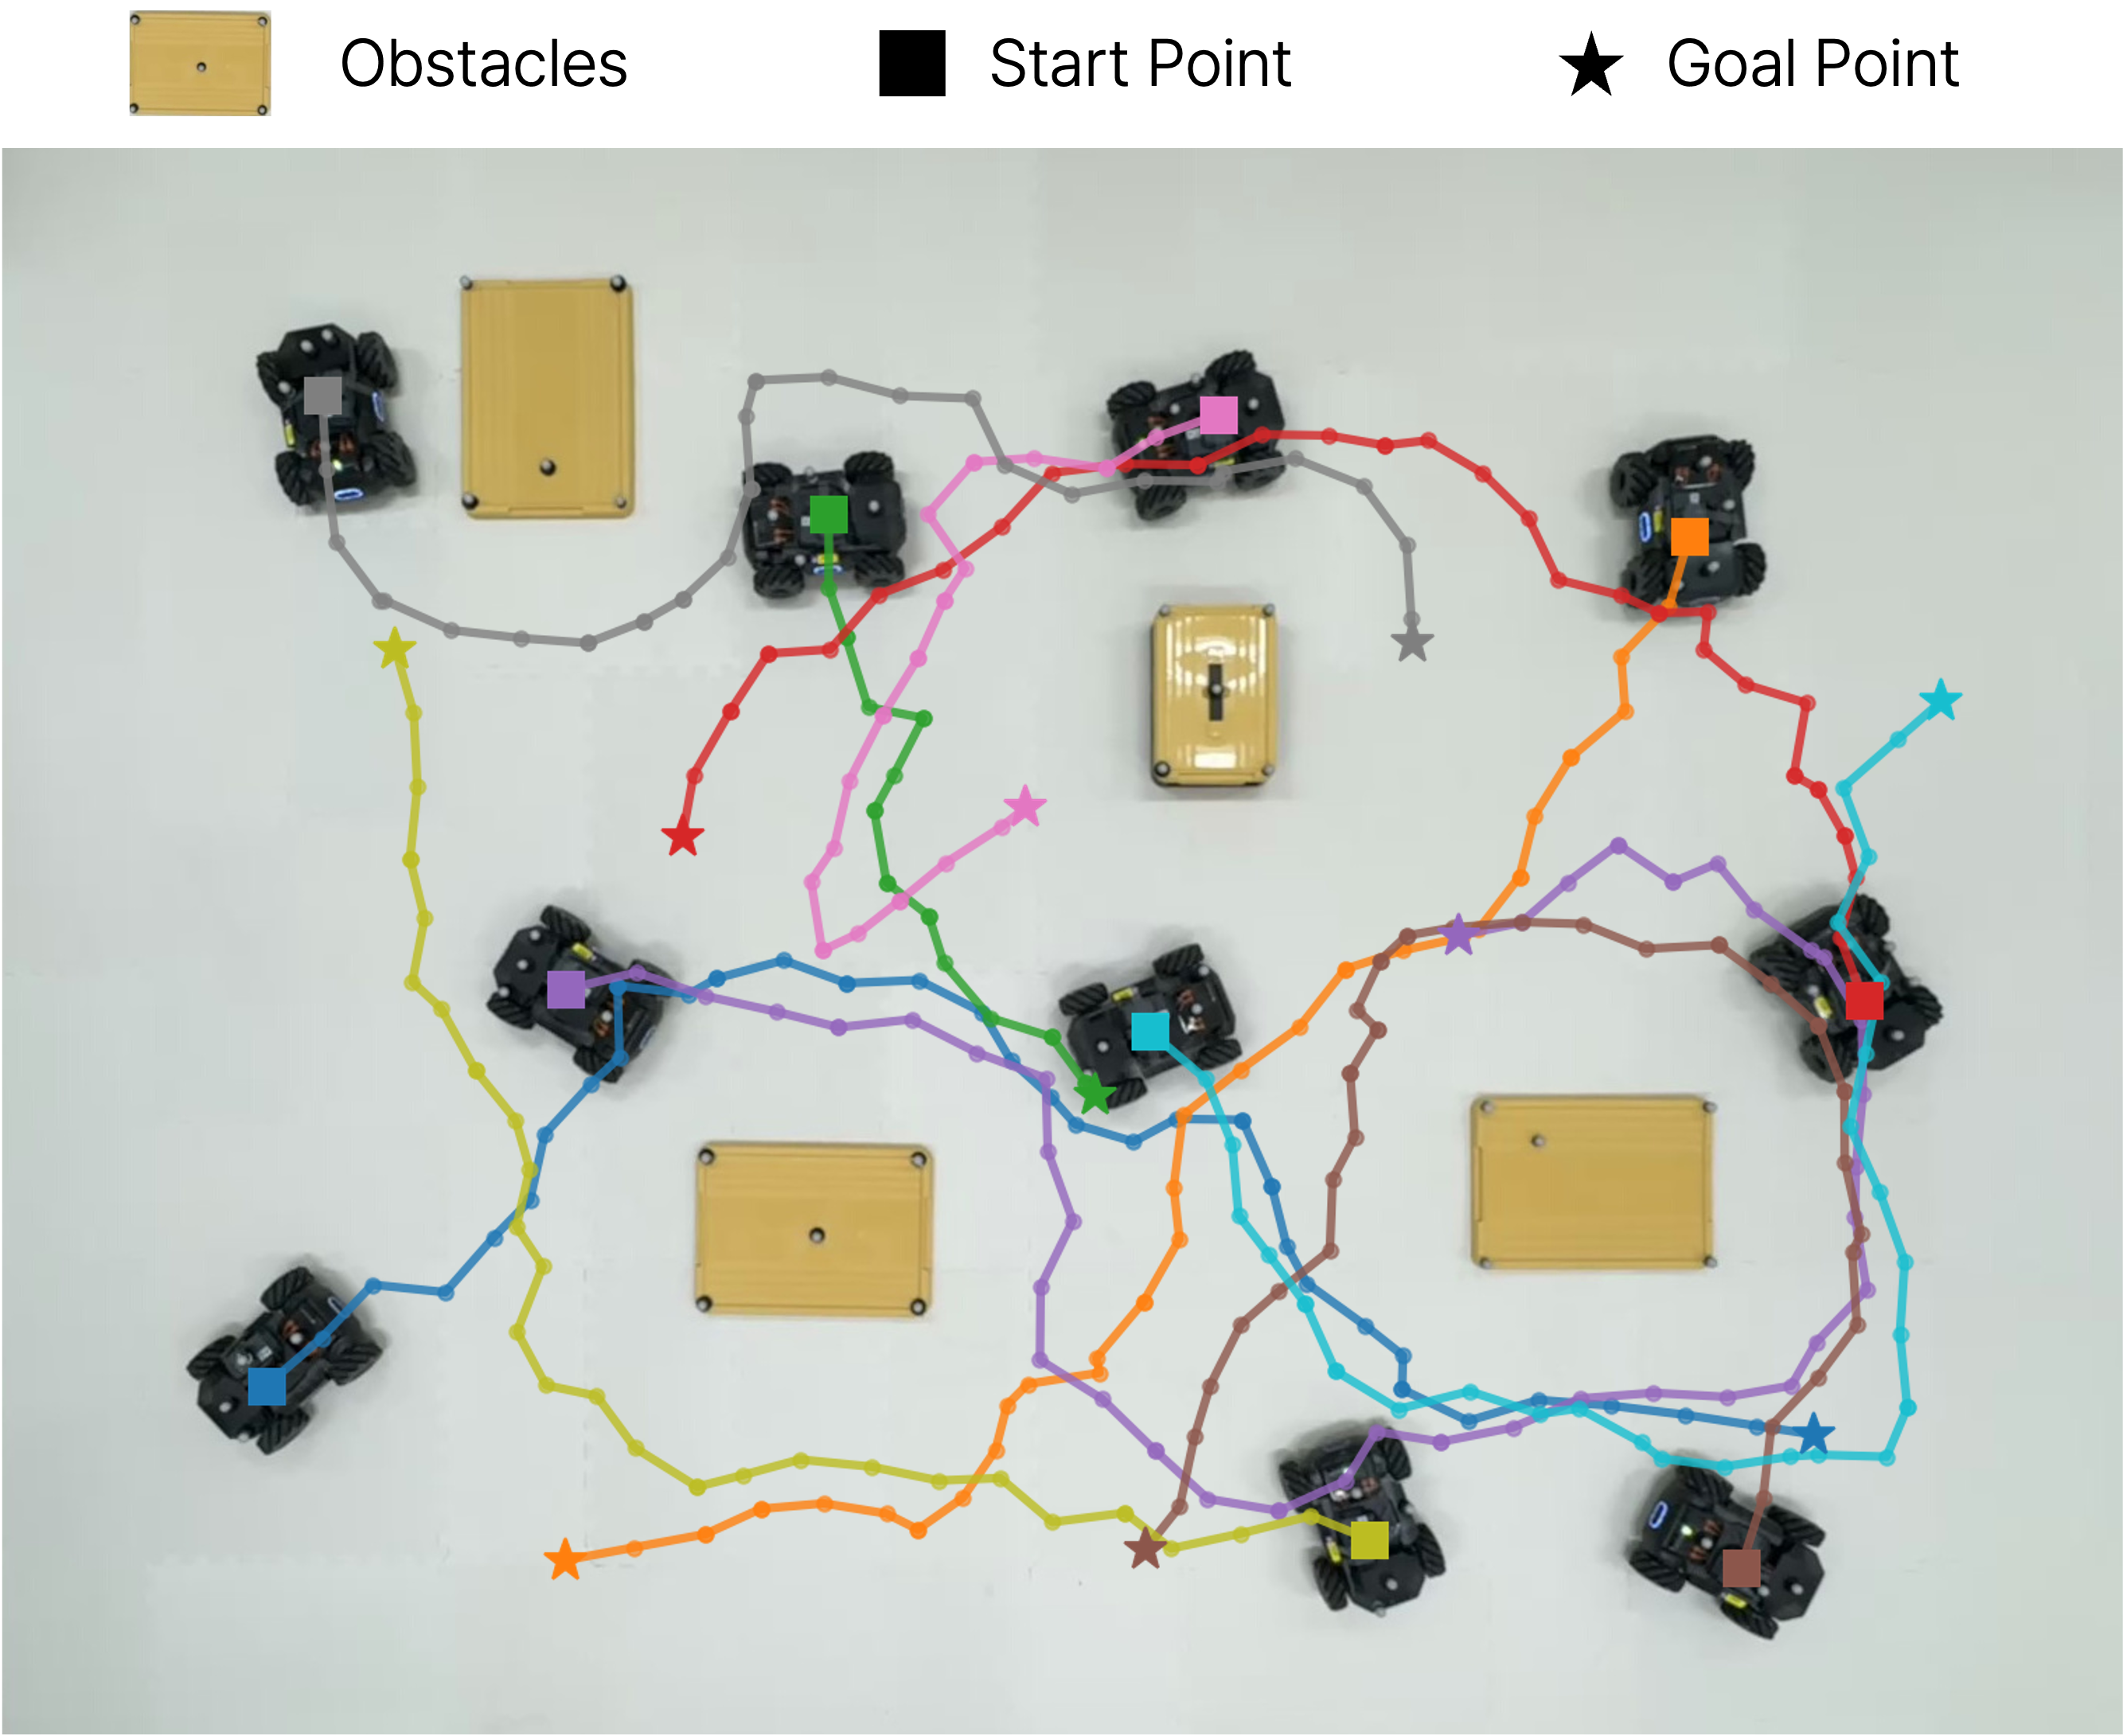
Joonyeol Sim, Joonkyung Kim, Janghyun Cho, Changjoo Nam Submitted, 2026 Two-level approach in which the low-level is a sampling-based single-robot path planner, Safe Interval RRT* (SI-RRT*), that finds a collision-free spatio-temporal trajectory for an individual robot. |
Work in ProgressMulti-Floor Multi-Agent Pickup & Delivery Multi-Agent Scene Graph Construction |
Academic Service
Reviewer: ICRA 2026,
ICCAS 2026
|
|
Design based on Jon Barron's website. |